Six-axis manipulation
A collaborative six-axis arm intended to reach around, under and into confined spaces with the freedom of a human wrist.
Reach in without stepping in.
This system is currently under development at Robotech s. r. o. and is not yet available for delivery. The specifications on this page are design targets rather than measured values, and the imagery is concept visualisation of the intended configuration. Timelines, figures and final configuration are subject to change as development progresses.
Suspect ordnance, an unidentified container, a contaminated sample — the work still has to be done by hand. EOD ARM is being developed to put that hand at the end of a six-axis manipulator instead of at the end of an operator's arm.
Mounted on the MRAZ3 tracked platform, the arm is designed to approach, inspect, grip, lift and place tools while the team stays at standoff distance. Nothing about the task changes. Only who is standing next to it. The system is in active development — we are building this capability now.
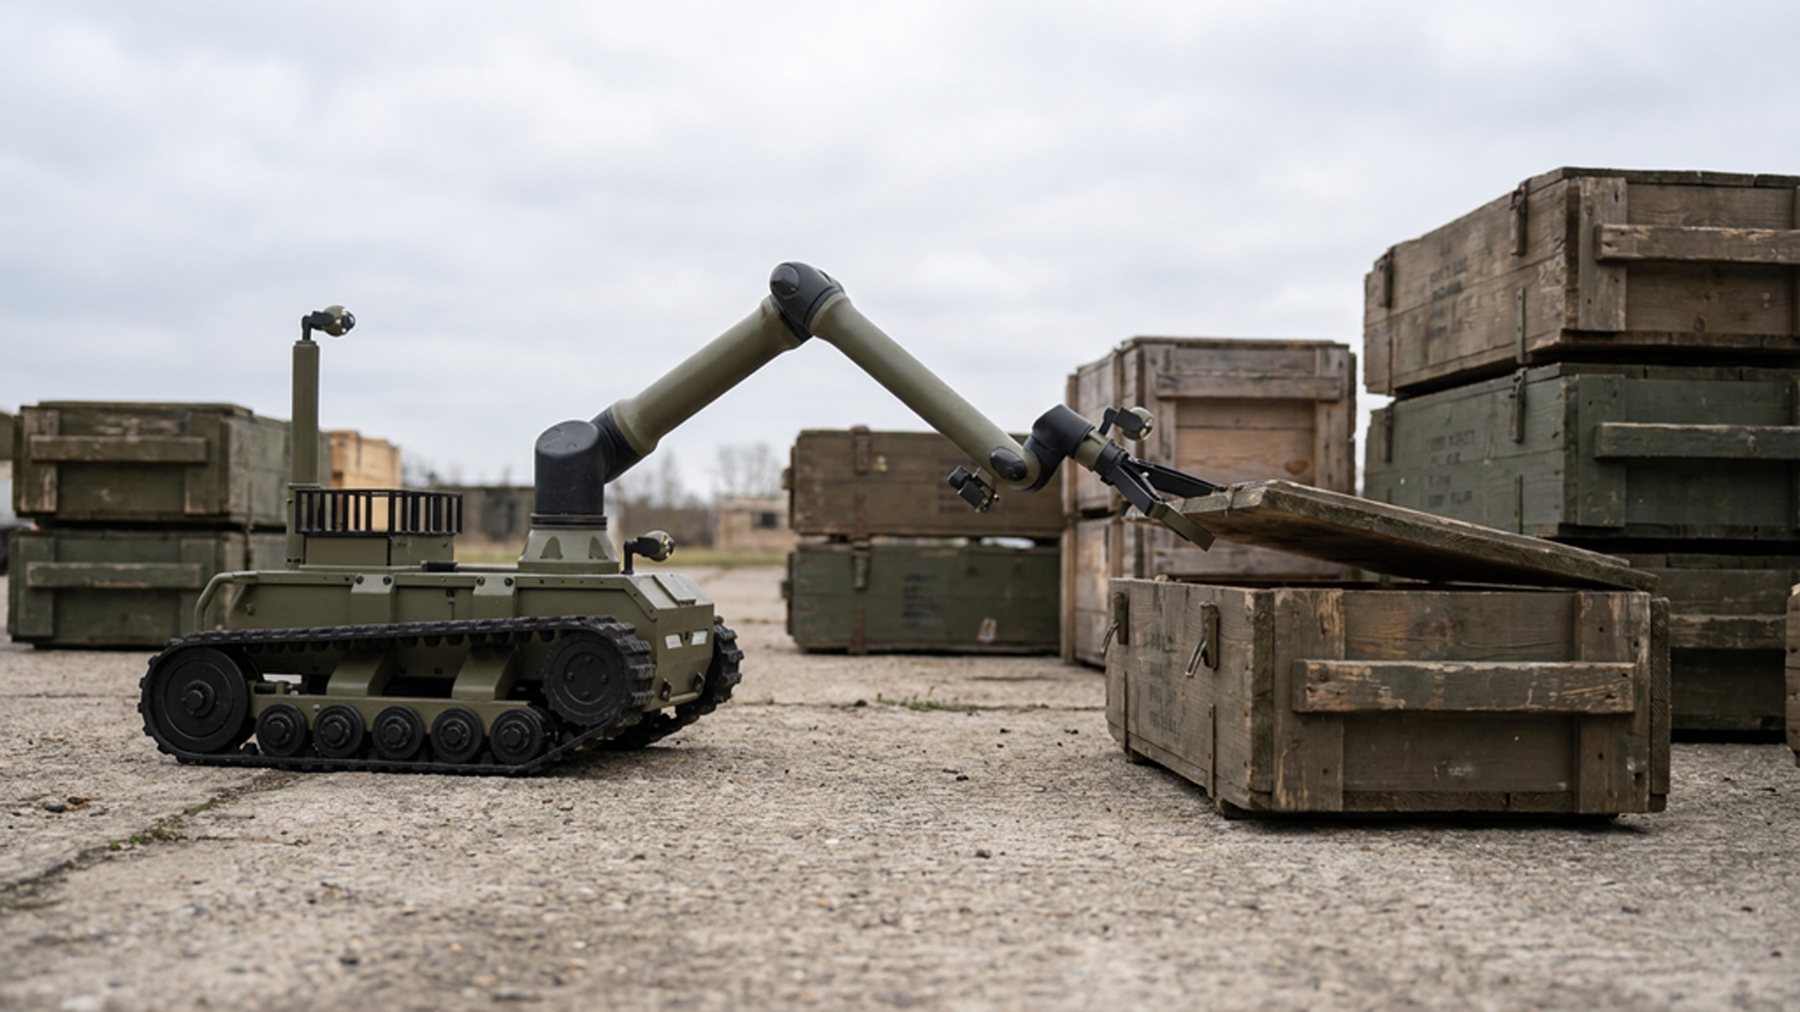
Target capabilities under development. Every one of them serves a single purpose: let the team do the whole job without closing the distance to the threat.
A collaborative six-axis arm intended to reach around, under and into confined spaces with the freedom of a human wrist.
Grippers and task tools designed around a common interface, so one arm can cover inspection, lifting and neutralisation.
The operator works the object through the platform. Removing direct exposure from the procedure is the core design goal.
Planned wireless radio teleoperation for mobility, plus secure fibre optic where the RF environment cannot be trusted.
Developed to fit the MRAZ3 platform as a module, so the same chassis can carry a different payload on the next task.
One manipulator intended to cover explosive ordnance disposal, CBRN sampling and hazardous material handling.
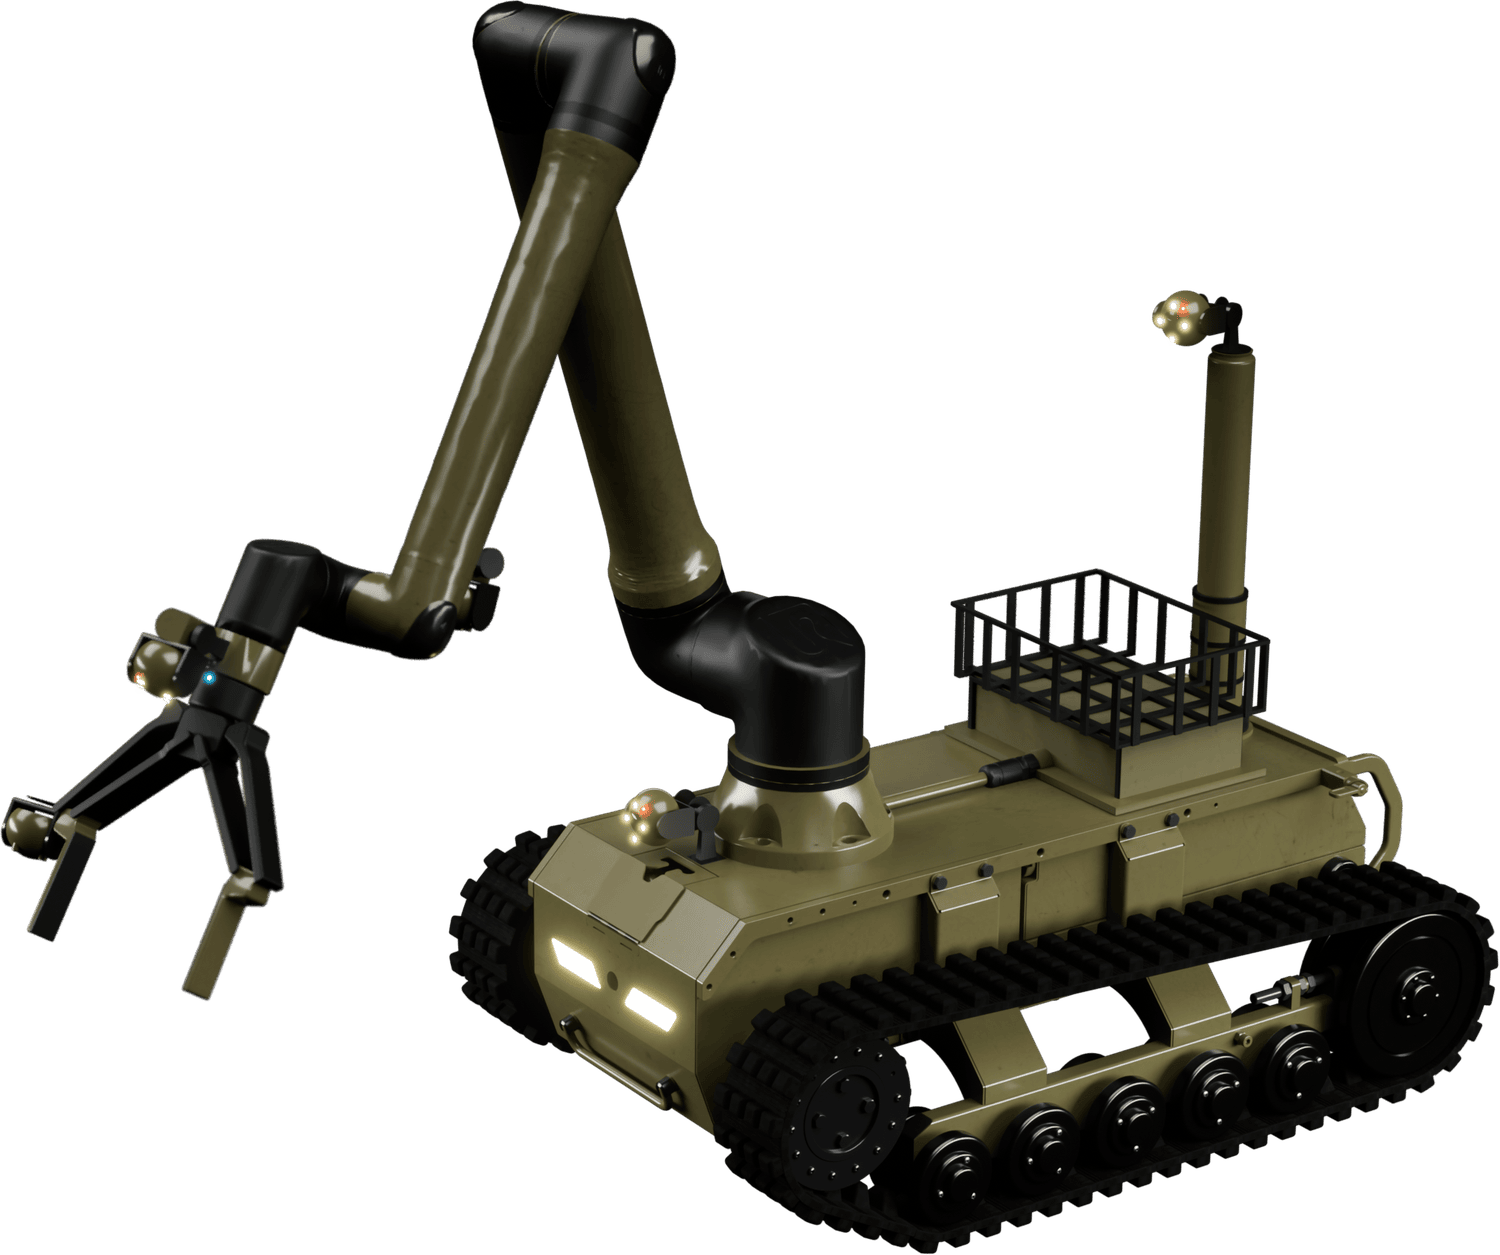
All figures are design targets for a system in development, not measured values from a finished product, and are subject to change. Platform figures refer to the MRAZ3 base vehicle and require confirmation for this configuration. Values marked [ TBD ] are not yet defined.
How the system is intended to be used once development is complete — four steps from cover to clear.
The arm module is to fit to the MRAZ3 platform and the vehicle moves out.
The operator drives to the object from cover and holds at working distance.
Cameras on the arm and chassis put the object on screen before anything is touched.
Grip, lift, open or place tools — the work the team would otherwise do by hand.
Rendered visualisations of the intended configuration. These are not photographs of a delivered system.
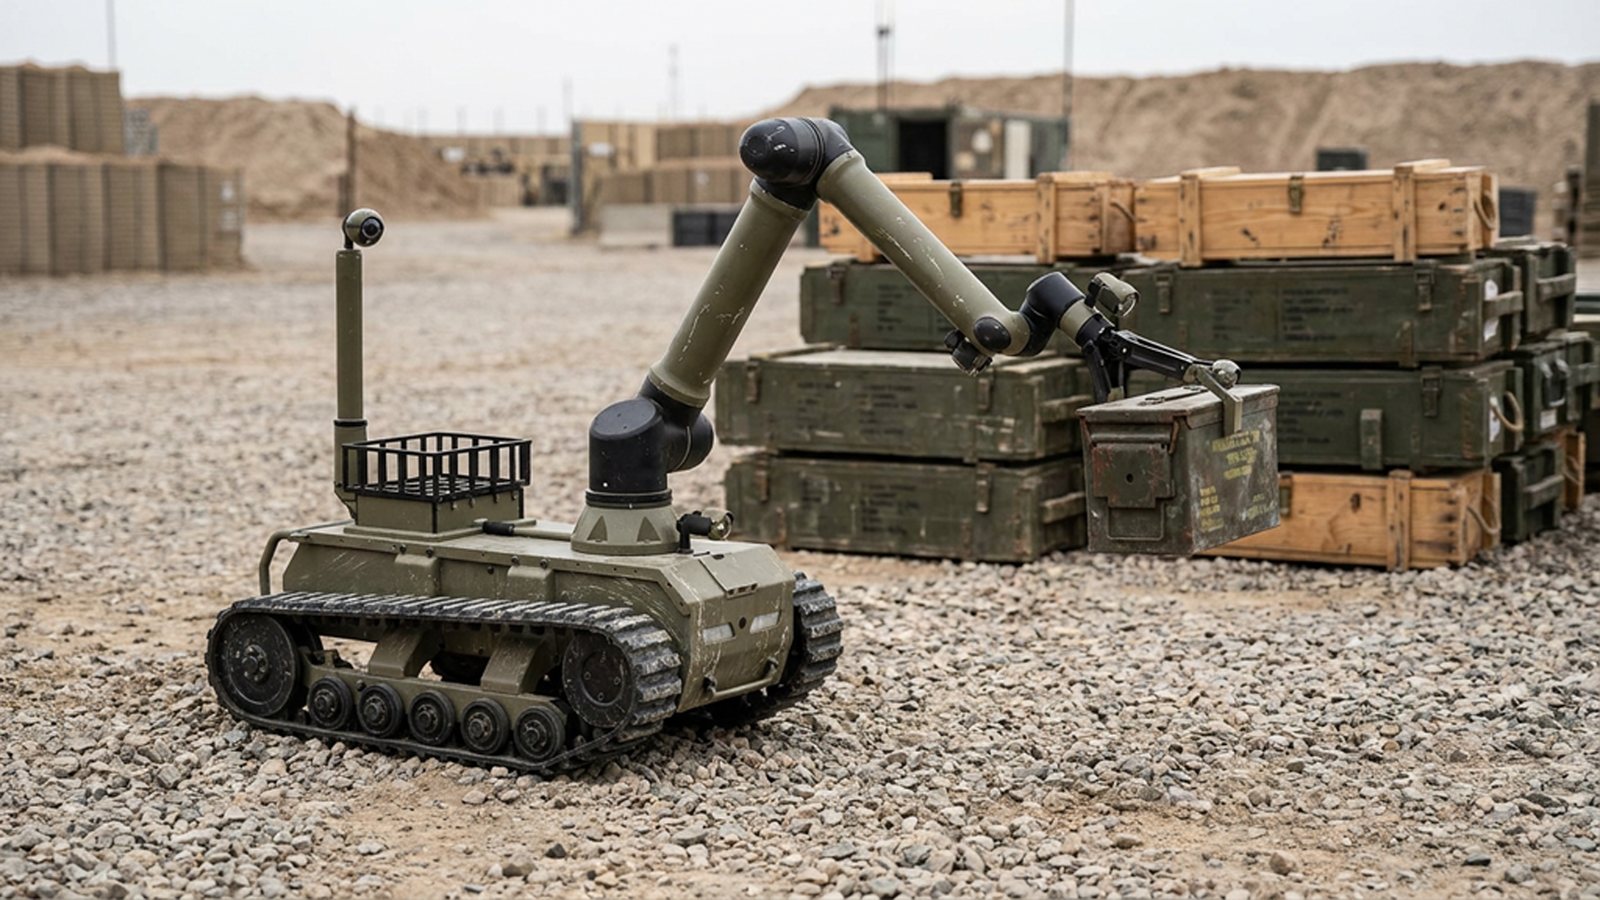
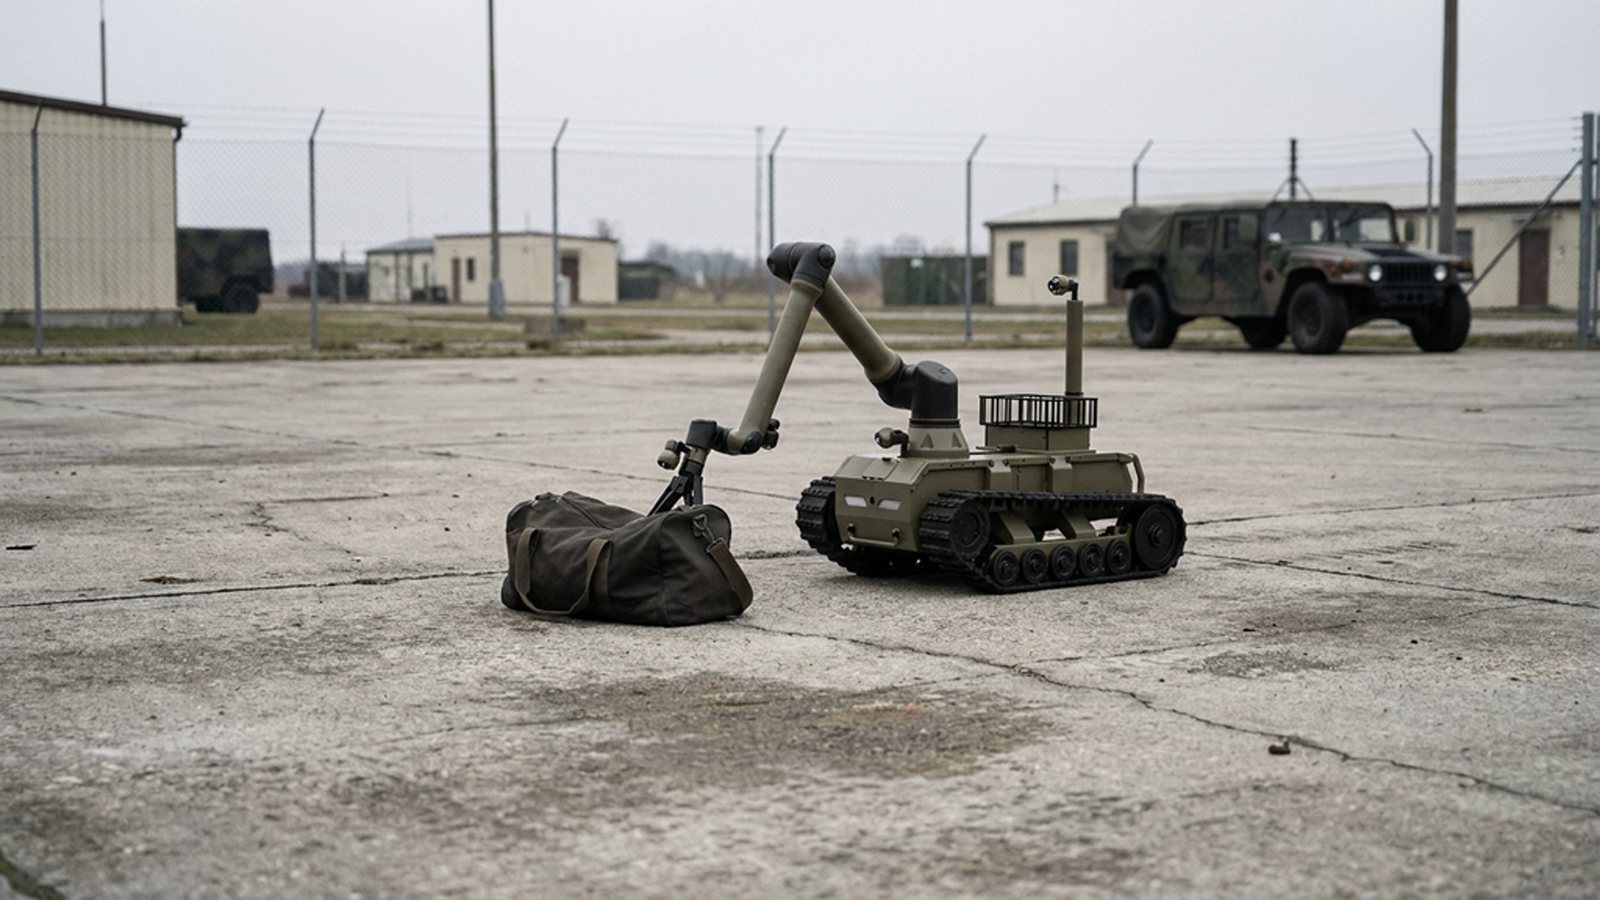
Concept renders · not a delivered system
The system is not yet available for delivery. For development updates, technical discussion or early-stage collaboration, contact us directly.